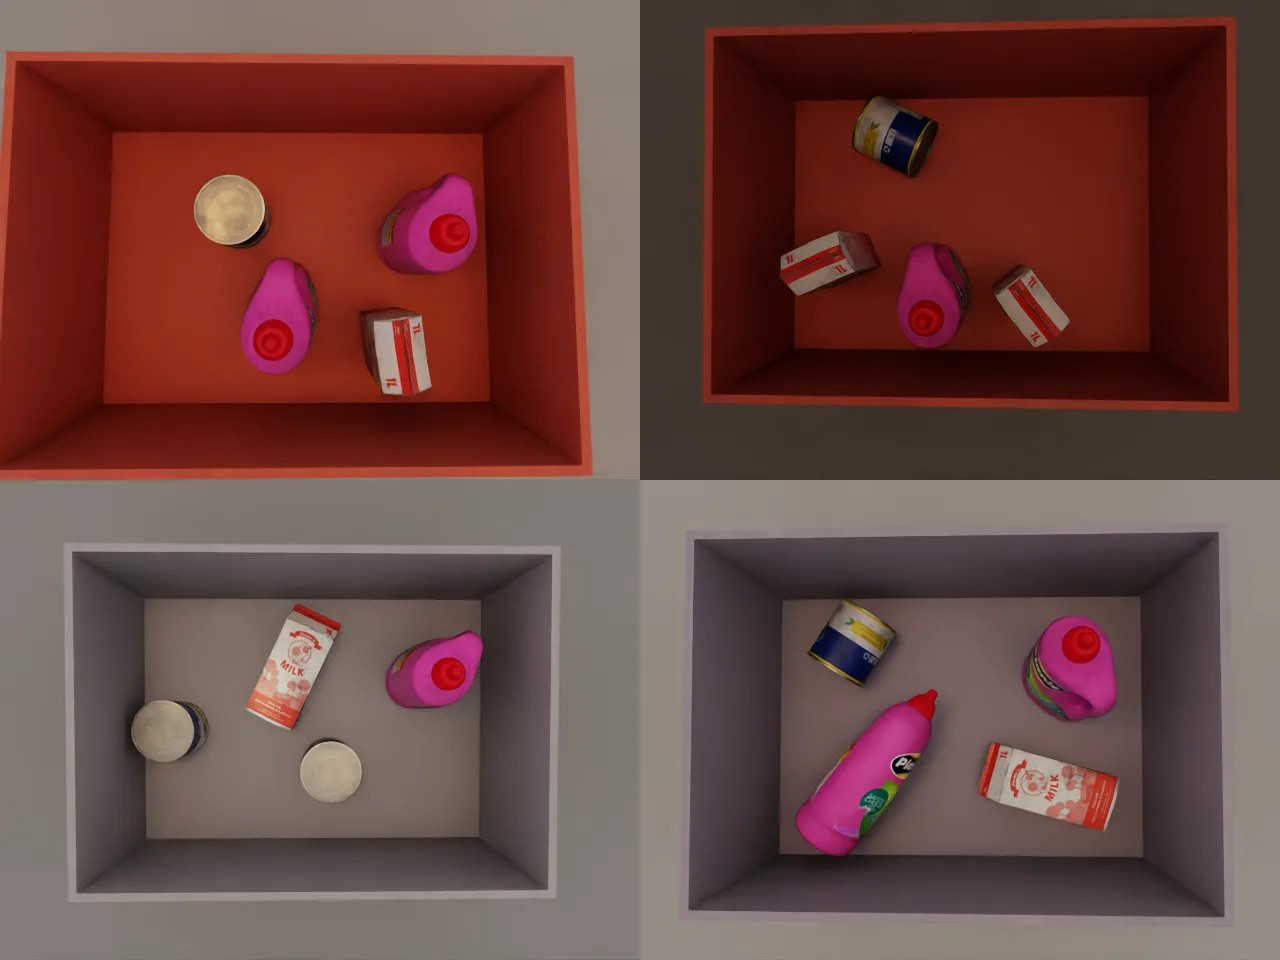
See the products
Synthetic images teach a vision model to locate products in a tote. Simulated scores are a starting point, not proof of real-world performance.
Read the experimentNock AI Robotics Lab
Robot vision, manipulation, and retail economics. Open experiments on what it takes to make a useful robot.
Follow a three-item basket from secured inventory to a pickup window. The interactive model explores geometry and motion; it does not establish hardware reliability.
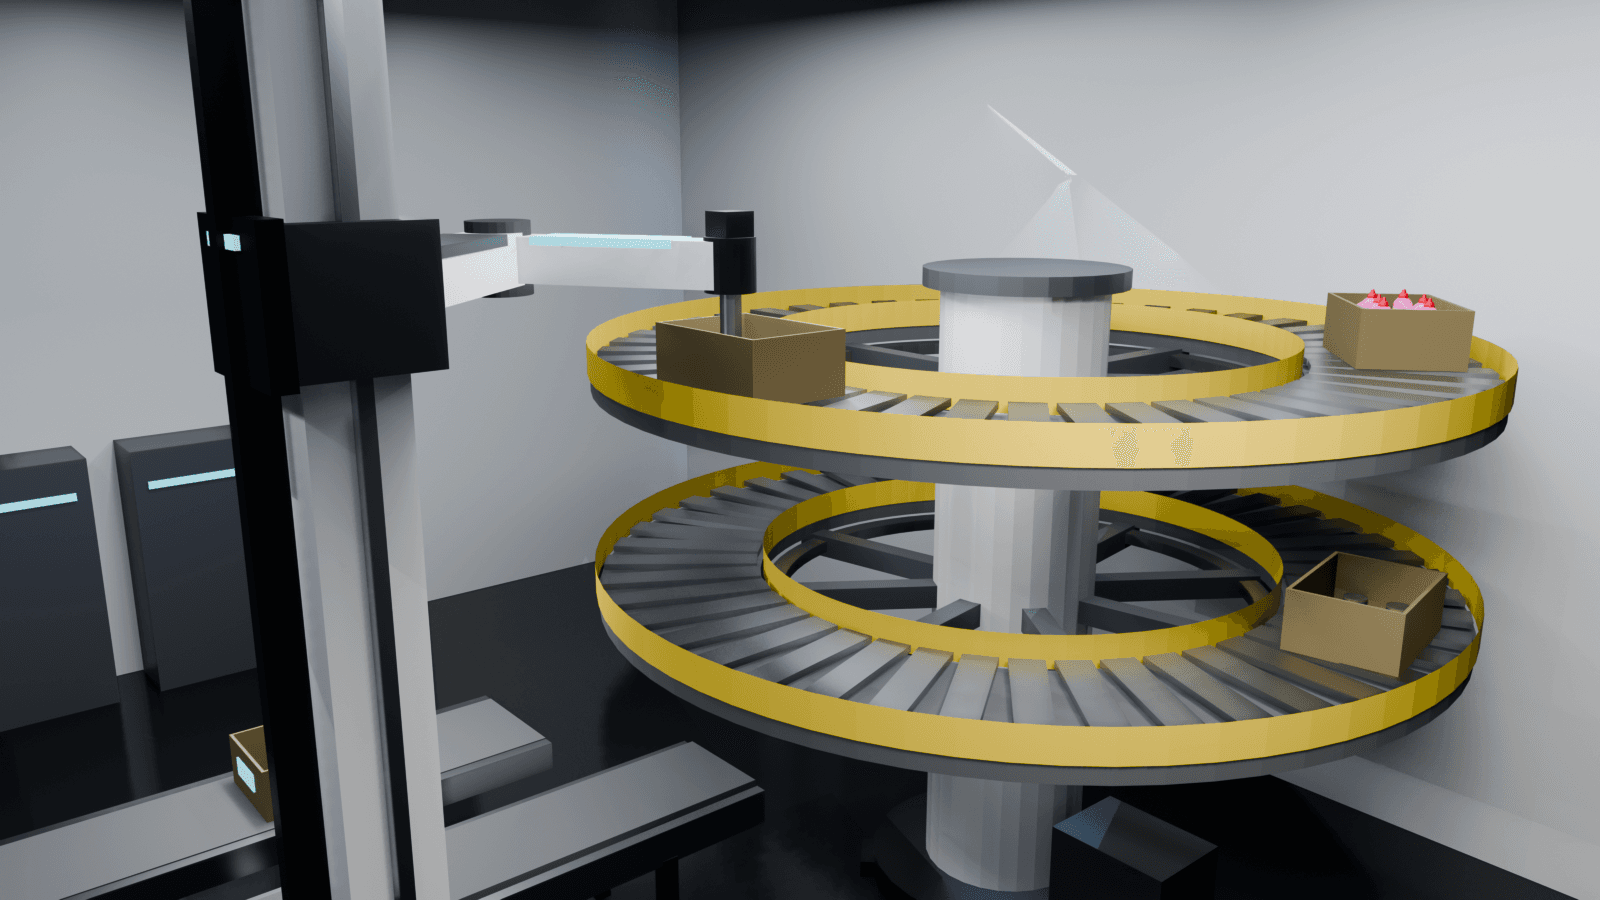
Two decks
0.0s
Two decks
The nominal simulated cycle is 34 seconds. Grasp reliability, recovery, safety, replenishment, and real-world throughput still need physical validation.
Read the full Retail Lab hypothesisSynthetic images teach a vision model to locate products in a tote. Simulated scores are a starting point, not proof of real-world performance.
Read the experiment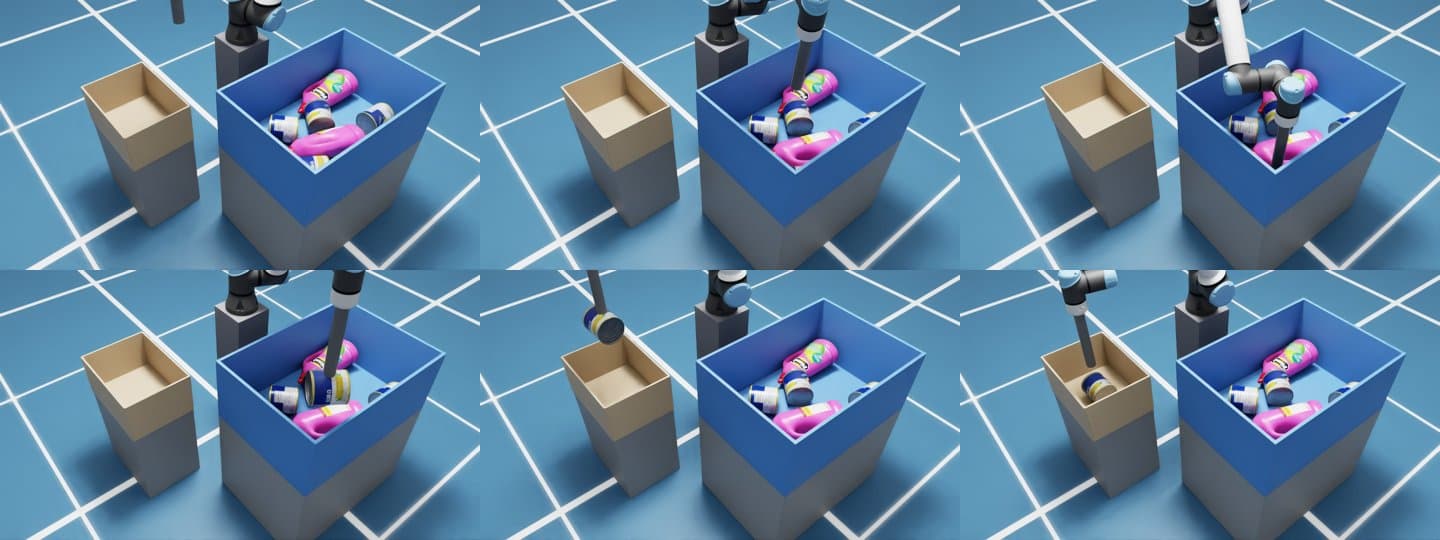
A simulated arm selects a grasp from camera input. The reported 59% simulation success rate makes the remaining failures part of the research.
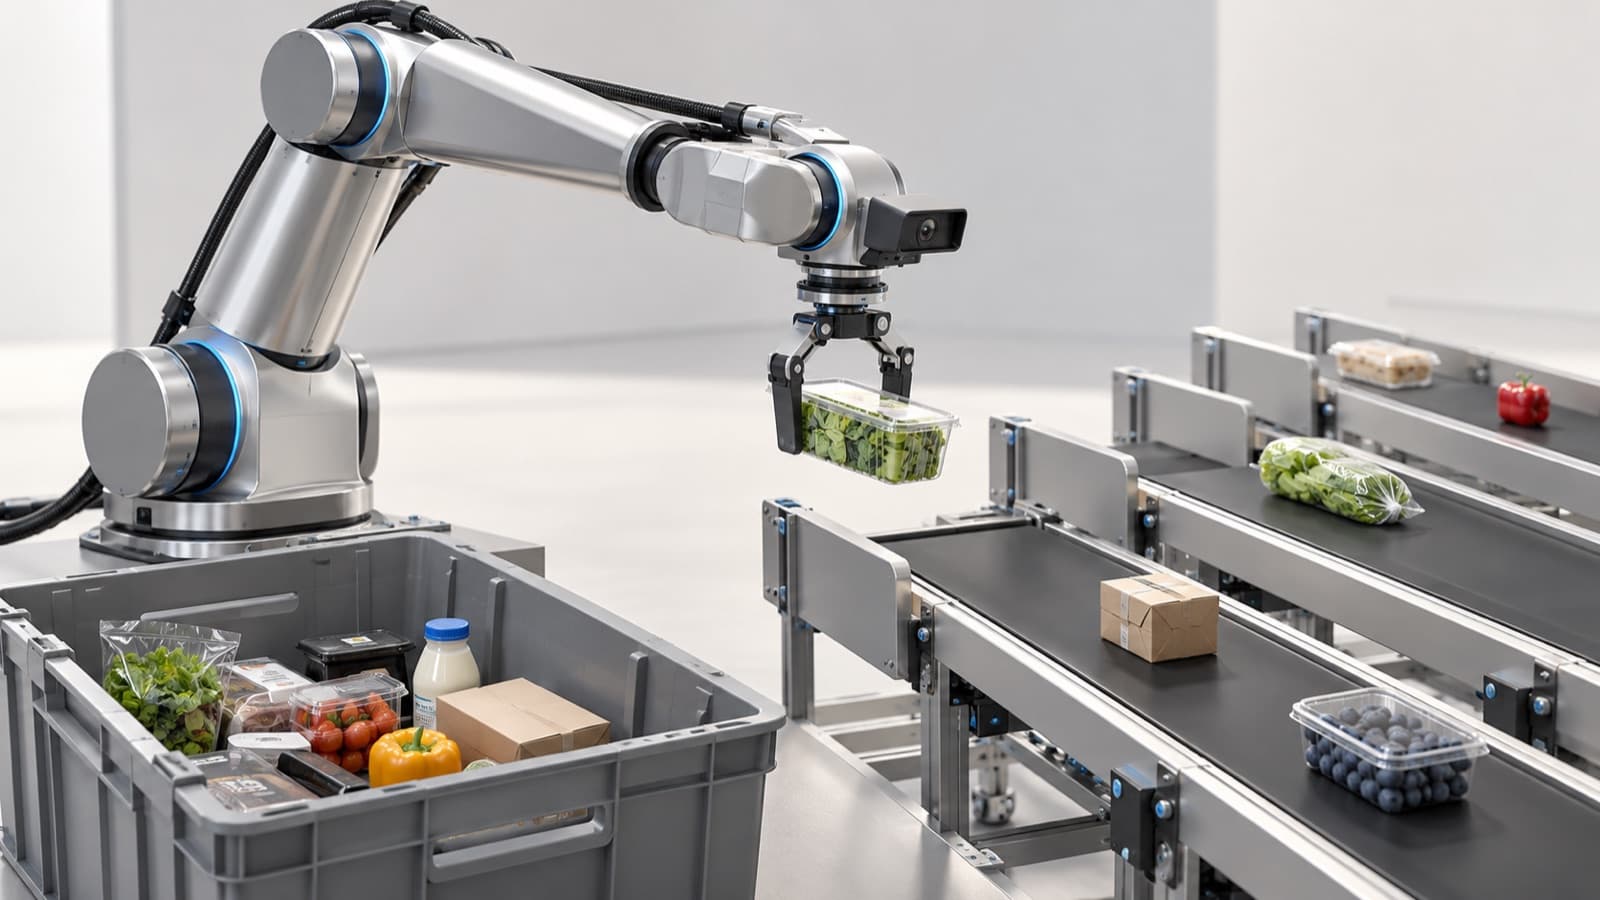
Read the experimentChange installed cost, labor, operating expense, and demand. See how quickly a plausible business case can disappear.
Test the model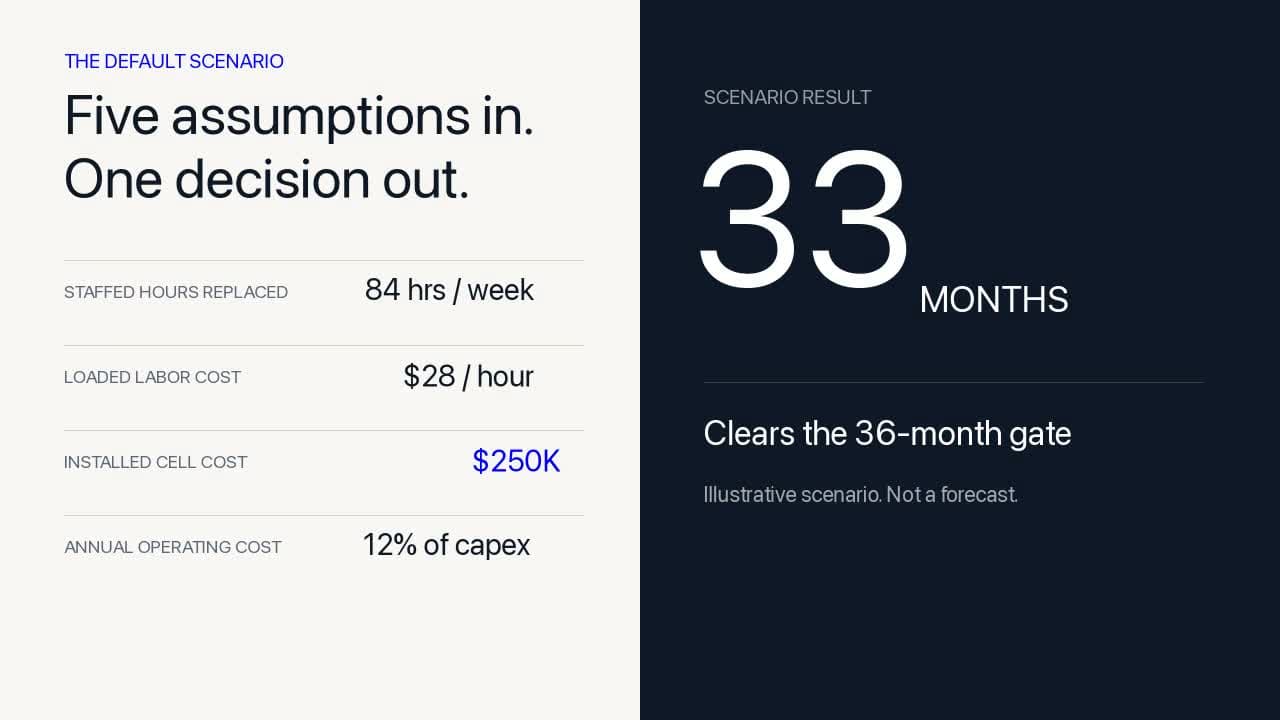
Experiments, industry analysis, and what we still need to prove. Our simulations are distinguished from other companies' reported deployments.
Ultra, a Brooklyn robotics company, just raised a $50 million Series A. Its robots pack real warehouse orders, and customers pay every month. Here is what a working robot business looks like, and what we take from it.
We built an interactive cost model for the Retail Lab. Its default case reaches payback in 33 months. Change one assumption and it takes 65. That sensitivity is the point.
OpenAI put the harness behind Codex into a public beta API. The runtime problem is getting solved for you. The process problem is not.
Collaborate with the lab.
We want to hear from robotics engineers, operators, and potential pilot hosts. Bring a real task and the constraints that matter.
Get in touch